DRONE MAPPING BRIEFING 01
DBV Underground Drone Mapping
Map Beyond the Brow. Get the Data Back Faster.
The DBV Underground Drone is purpose-built for GPS-denied underground mine mapping—taking high-density LiDAR into stopes, raises, voids and inaccessible openings where conventional survey access is difficult or impractical.
Your opening. Your survey cycle. Your numbers.
±5 MM
Published LiDAR Accuracy
150 M
Flight LOS Range
5.2M
Points / Second
2 × 1 M
Accessible Opening
Where Does Underground Survey Time Disappear?
Equipment Has to Reach the Right Position
Conventional underground survey workflows may require equipment setup at a brow, opening or accessible survey position before data collection can begin. Every setup consumes part of the shift.
The Geometry You Need Is Often Beyond Direct Access
Stopes, voids and post-blast openings are precisely the areas where visibility and physical access can become difficult. A fixed observation position can also leave unseen geometry behind corners, brows or irregular surfaces.
One Position Does Not Always See the Whole Opening
Complex underground geometry can create shadowing and incomplete coverage. More positions or additional measurements may be required to understand the complete opening.
Missing Data Costs More Than the First Survey
If the team discovers incomplete coverage after leaving the heading, the cost is not simply another scan. It is another: trip → setup → capture → processing cycle.
The fastest survey is not the one that flies fastest. It is the one that gets usable underground geometry back to the team without another trip.
Fly the Scanner to the Geometry
Instead of trying to measure the entire opening from one accessible position, DBV carries SafeSight's LiDAR capture system into the underground space.
The drone becomes the mobility platform.
The SafeScanner becomes the data-capture platform.
Together they enable underground drone mapping beyond the limits of a fixed survey position.
LAUNCH
Deploy DBV from a controlled underground position.
NAVIGATE
Fly into GPS-denied underground openings using sensor-assisted flight controls designed for confined mining environments.
SCAN
Capture high-density LiDAR while moving through the opening.
VERIFY
Use Live Render to see the developing point cloud during the flight.
PROCESS
Move captured scan data into Eclipsed for cleaning, geo-referencing and processing.
USE
Visualize, measure, organize or transfer the resulting spatial data into the mine's engineering and planning workflow.
Published SafeSight field example. Results vary by site and workflow.
From 45 Minutes to 15 Minutes in a Published SafeSight Stope Example
Traditional CMS Example
Drone-Based LiDAR Example
Map Underground Areas Conventional Access Struggles to Reach
POST-BLAST VOIDS
Capture three-dimensional geometry after blasting where direct access or visibility is limited.
RAISES
Fly into suitable vertical or inclined openings when aerial access is the appropriate capture method. Where an installed Alimak rail is present, MRC Rail Runner may be the more suitable SafeSight platform.
ORE PASSES
Inspect and spatially document suitable inaccessible vertical openings where visibility from the collar does not provide enough information.
FALL-OF-GROUND AREAS
Remotely map areas where access restrictions prevent conventional field positioning.
UNSUPPORTED OPENINGS
Capture spatial information while reducing the need to position survey equipment or personnel inside the opening.
CONFINED UNDERGROUND CAVITIES
Use DBV where the geometry and access are appropriate for aerial LiDAR capture.
Underground Mapping Without GPS
A surface drone normally depends heavily on GNSS/GPS positioning.
Underground, that signal is unavailable.
DBV is built specifically for these GPS-denied environments.
ACTIVE OBSTACLE DETECTION
Dedicated sensors monitor the environment around the drone during flight.
VIRTUAL PROTECTION ZONE
A monitored protection zone is maintained at propeller height, where collision risk is highest. Onboard processing and a dedicated micro LiDAR sensor continuously detect nearby obstacles before contact occurs.
ASSISTED POSITION CONTROL
Position-control and hover assistance help the pilot manage the aircraft in confined underground environments.
NO GPS REQUIRED
The system is designed specifically for environments where satellite positioning is unavailable.
See the Point Cloud While the Drone Is Still Underground
Capturing data quickly is useful. Knowing you captured the right data is more valuable.
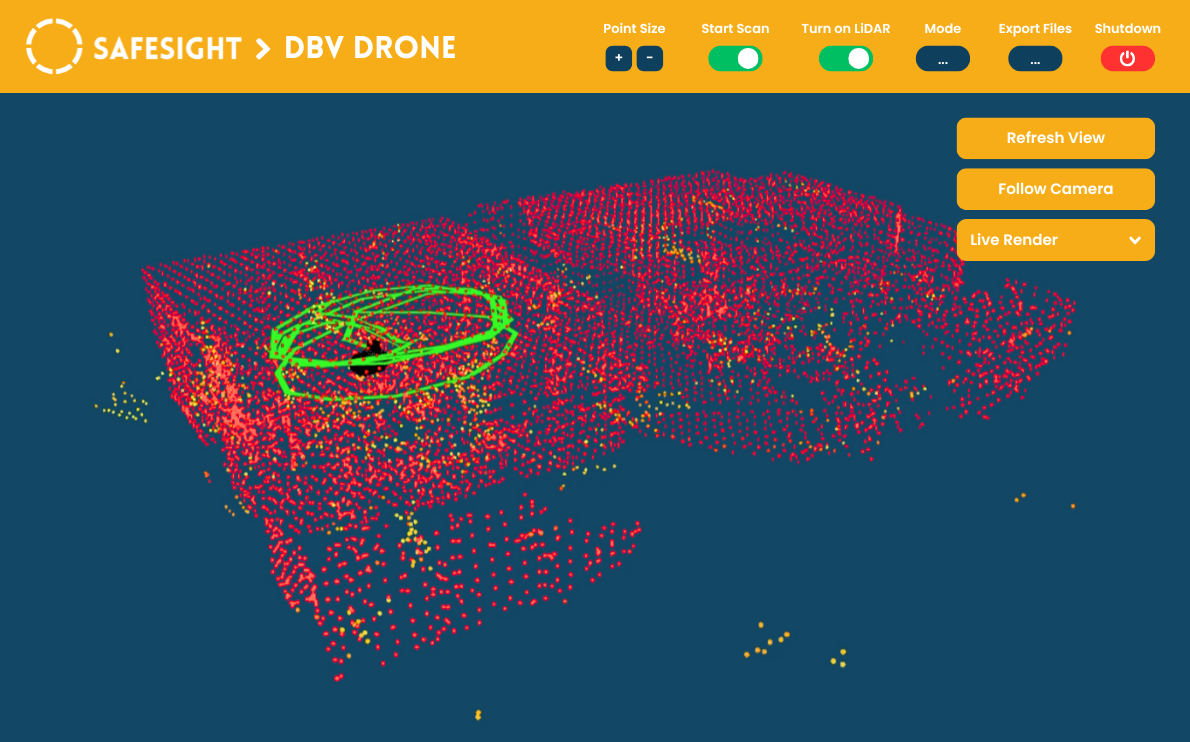
SafeSight's Live Render workflow displays the developing point cloud as the scan progresses, allowing the operator to evaluate coverage before ending the underground mapping mission.
Verify Underground Mapping Before Leaving the Heading.
If an important area appears incomplete, the operator can identify it while the drone and survey team are still positioned for the job rather than discovering the gap later during office processing.
From Underground Drone Mapping to Engineering Data
DBV DRONE
Carry LiDAR into GPS-denied and difficult-access underground openings.
CONTROL APP
Monitor scan progress and evaluate coverage during capture.
ECLIPSED
Clean, geo-reference and prepare point-cloud data.
NIMBVAULT
Organize, visualize, measure and retain underground spatial information.
MINE PLANNING
Move relevant data into established survey, engineering and planning workflows.
The Difference Is Where the Sensor Can Go
| FIXED-POSITION / CONVENTIONAL CAPTURE | DBV UNDERGROUND MAPPING |
|---|---|
| Sensor remains near accessible position | Sensor travels into suitable underground geometry |
| Coverage depends heavily on line of sight | Moving capture can view geometry from multiple positions |
| Complex geometry can produce shadow areas | Flight path can improve visibility of hidden surfaces |
| Additional setup positions may be required | One mobile capture platform |
| Survey data often reviewed after capture | Live Render supports field verification |
| Appropriate for many conventional requirements | Particularly useful for inaccessible and difficult-access openings |
Use the Right Tool for the Opening — Not the Same Tool for Every Survey.
Better Stope Visibility Supports Better Reconciliation
An incomplete cavity model can affect more than the visual quality of a point cloud.
Captured geometry can support decisions involving:
- actual excavation volume;
- design compliance;
- overbreak and underbreak;
- dilution and remaining ore;
- backfill and future blast design;
- reconciliation.
DBV allows the capture platform to move through suitable openings instead of trying to understand the entire cavity from a single point of view.
Stop Measuring the Drone in Flight Time.
Measure the Mapping Workflow.
A mine does not receive value because a drone remained airborne for a certain number of minutes. The value comes from what the entire mapping workflow allows the technical team to accomplish faster.
LESS FIELD TIME
How long from setup to completed underground capture?
FEWER SURVEY SETUPS
How many equipment positions are currently required to understand the opening?
LESS REWORK
Can the team confirm coverage before leaving?
FASTER DATA AVAILABILITY
How long before captured geometry becomes usable by technical teams?
MORE SURVEY CAPACITY
Could the same survey team complete more underground mapping in the same shift?
DBV Underground Drone Specifications
| Published LiDAR Accuracy | ±5 mm |
| Flight LOS Range | 150 m line of sight (70 m beyond line of sight) |
| Scan Speed | Up to 5.2M points/sec |
| Flight Accessibility | Minimum opening of 2 m × 1 m |
| GPS-Denied Environment | No GPS required for flight operations |
| Camera | 1080p HD, Low Light FPV Camera |
| Dimensions | 27 × 27 × 20.5 in |
| LiDAR Range | 0–100 m (Underground) |
| Formats | PTS, LAS, DFX, XYZ |
| Scan Verification | Live Render 3D point cloud |
| Laser Safety | Class 1 (eye-safe) laser |
| Assistance Features | Collision prevention, position control (pilot assist) |
Underground Geometry Your Technical Team Can Actually Use
3D POINT CLOUDS
Dense spatial representation of the scanned underground opening.
MEASURABLE GEOMETRY
Review dimensions, shape and spatial relationships after capture.
STOPE MODELS
Understand cavity form and actual excavation geometry.
VOLUME ANALYSIS
Support reconciliation and material-volume calculations.
DESIGN-TO-AS-BUILT COMPARISON
Compare captured geometry with planned development.
HISTORICAL MAPPING
Repeat scans can create a spatial record of changing underground conditions over time.
Need the Underground Area Mapped Rather Than the Drone?
Some mining operations want to own and operate DBV. Others simply need the mapping result.
Where appropriate, SafeSight can support underground mapping and inspection workflows using the technology suited to the opening.
DBV = PRODUCT
STOPE INSPECTION / SURVEYING = SERVICE OUTCOME
Built Around Underground Mapping, Not Surface Flight
Many drones are excellent surface aircraft. Underground mapping creates a different challenge:
- no GPS;
- darkness;
- irregular rock geometry;
- narrow access;
- unsupported openings;
- dust;
- collision risk.
The DBV product is not a surface drone attempting to fly underground. It is an underground drone mapping system designed specifically for the environment and the survey data required.
Underground Drone Mapping FAQ
Does DBV require GPS to fly?
No. DBV is designed specifically for GPS-denied environments. It uses dedicated sensors and pilot-assist position control to navigate underground headings where satellite signals are unavailable.
Can we see the scan data during the flight?
Yes. SafeSight's Live Render workflow allows the operator to view the developing 3D point cloud on the control screen while the drone is in flight. This helps verify coverage before leaving the site, reducing the risk of incomplete data and rework.
What data formats does DBV output?
The system provides engineering-ready data compatible with major mine planning and engineering software. Standard outputs include PTS, LAS, DFX, and XYZ point-cloud formats.
What is the minimum opening DBV can fly into?
Based on current specifications, the minimum flight accessibility requires an opening of at least 2 meters by 1 meter. Actual accessibility depends on site conditions, geometry, and ventilation.
YOUR OPENING. YOUR SURVEY CYCLE. YOUR NUMBERS.